Robot Arm V2
April 2025
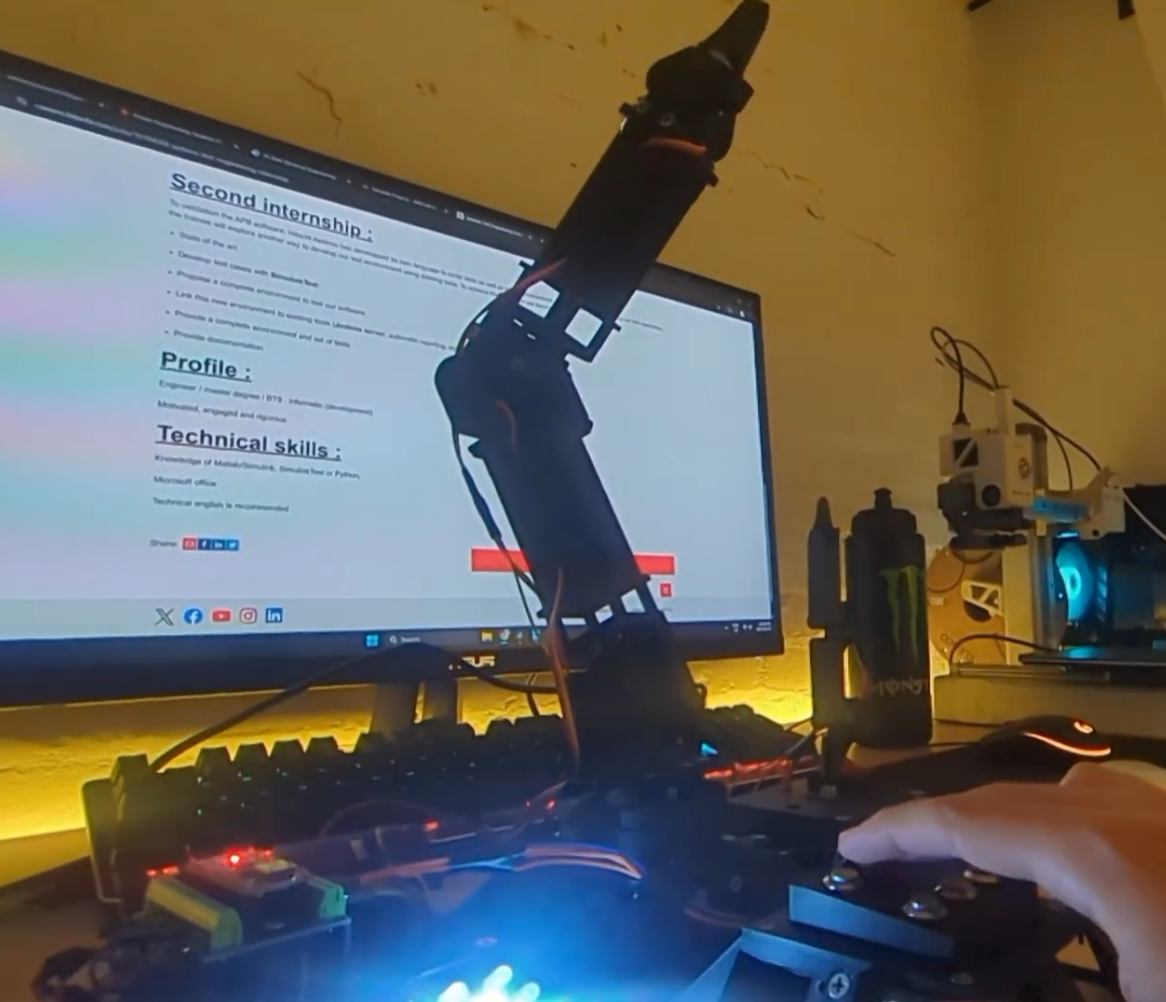
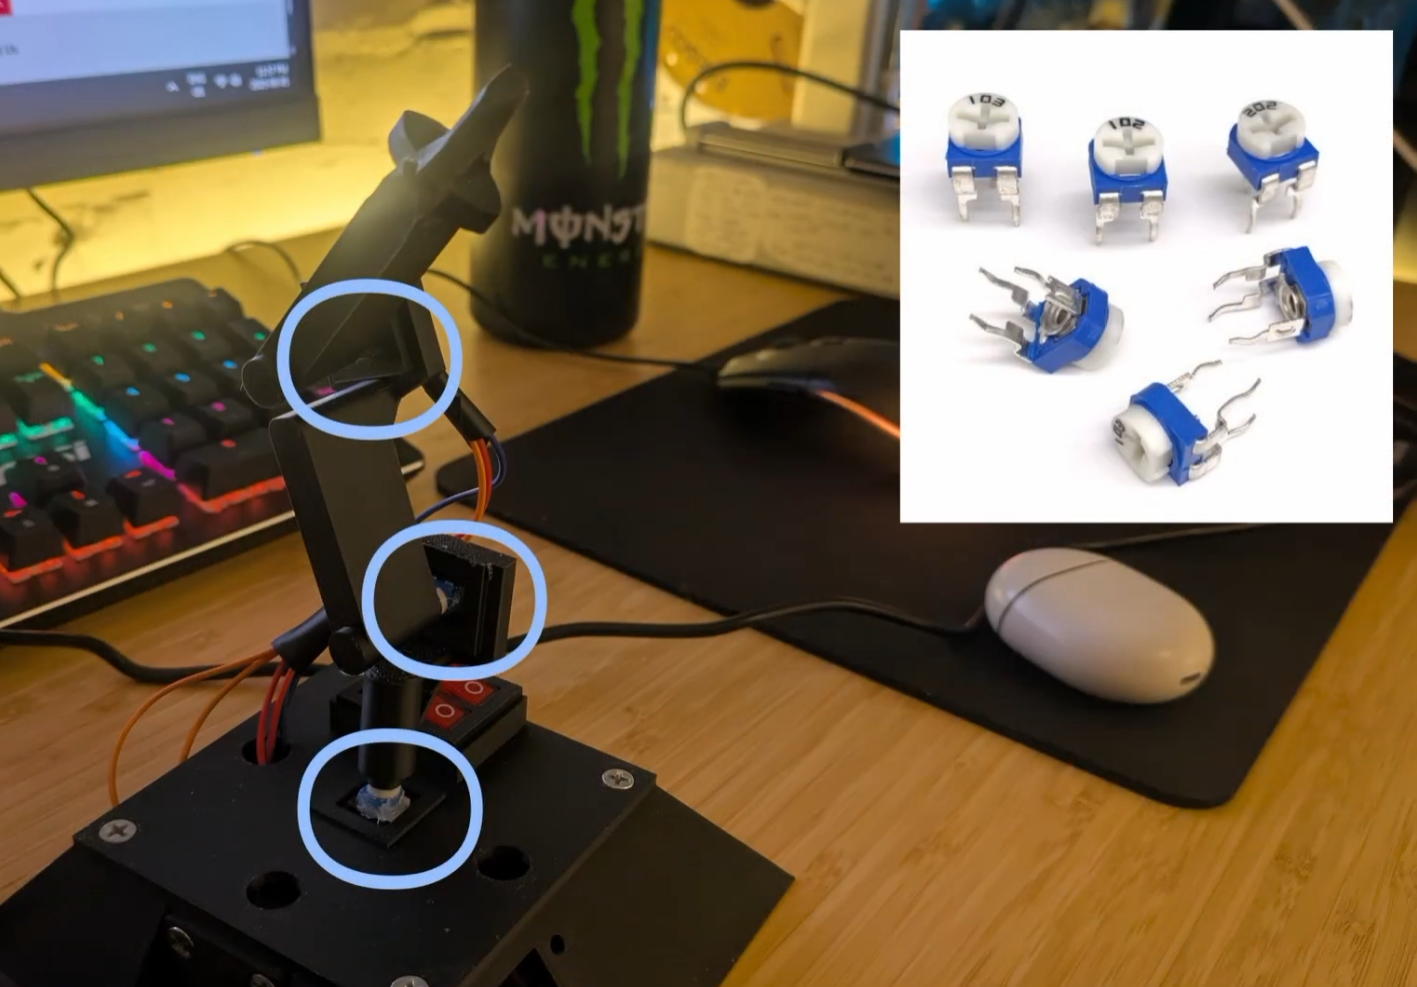
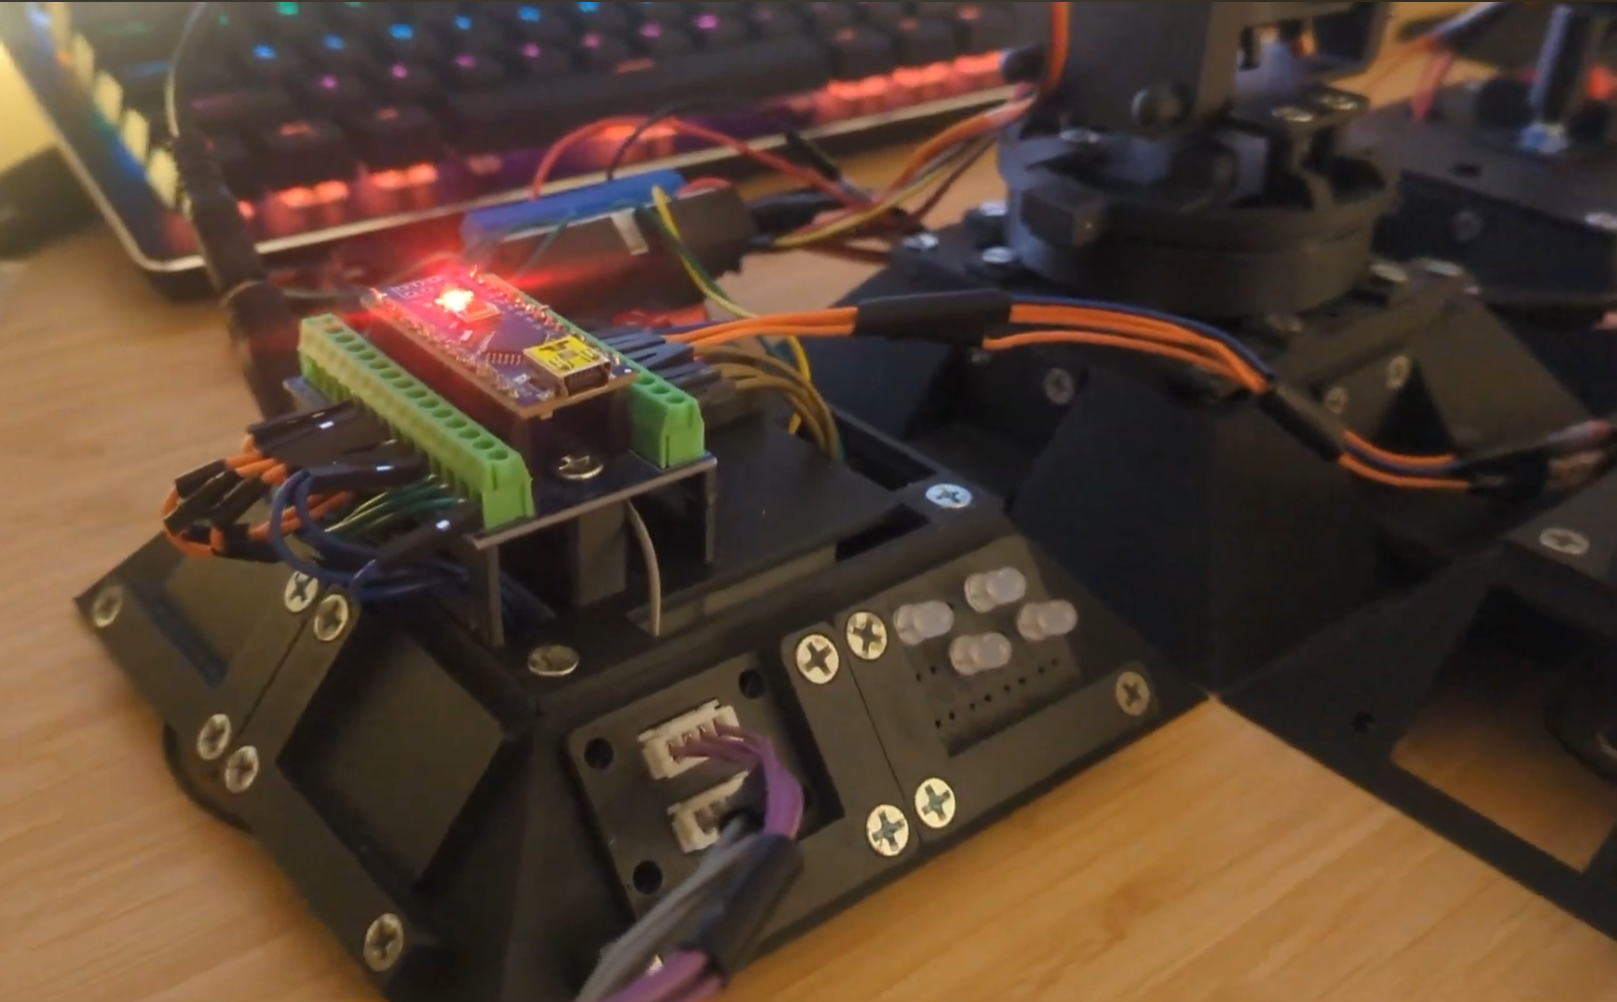
Through the first months of 2025 I made many upgrades to the original arm: * Added button control * Added a larger platform at the base of the robot for stability * Added reliable harnessing and an Arduino breakout board to make assembly simpler * Added a scaled-down model of the arm with potentiometers at the joints as a separate control scheme. * Added USB-C power input I would love to revisit this project at some point with the knowledge I have now. Having a 5-axis arm with custom motor driver PCBs (no more servos) would be totally awesome.